Problem
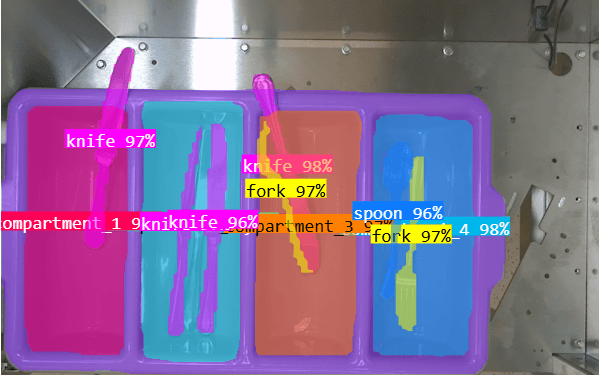
Automating the handling of different types of cutlery presents challenges in object recognition, classification and positioning. Spoons, forks and knives vary in geometry, orientation and placement, making reliable identification essential for subsequent automated handling operations.
Traditional automation systems often depend on predefined object positions or additional mechanical arrangements. Computer vision provides an alternative approach by extracting relevant information directly from images of the working area.